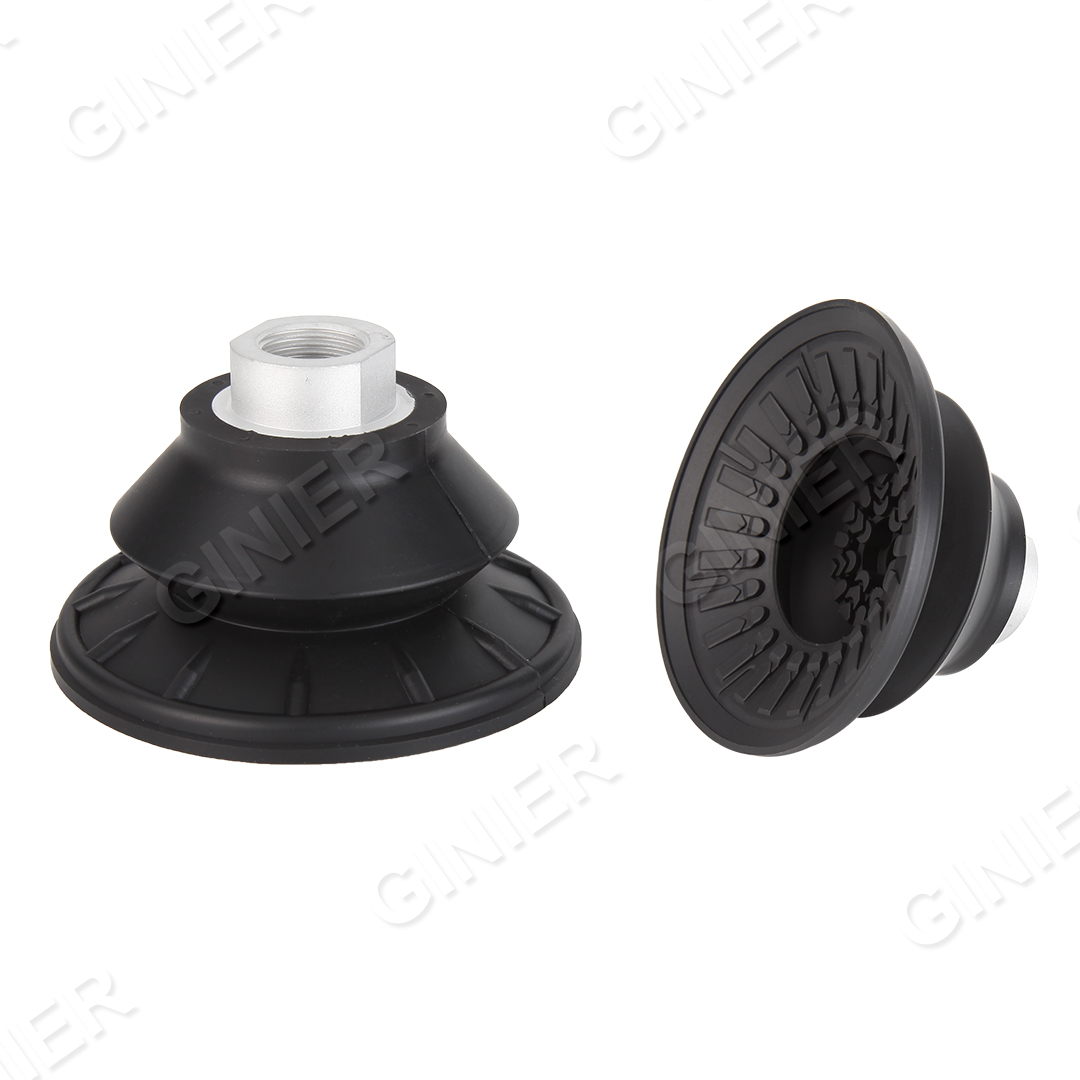
robot arm end effector
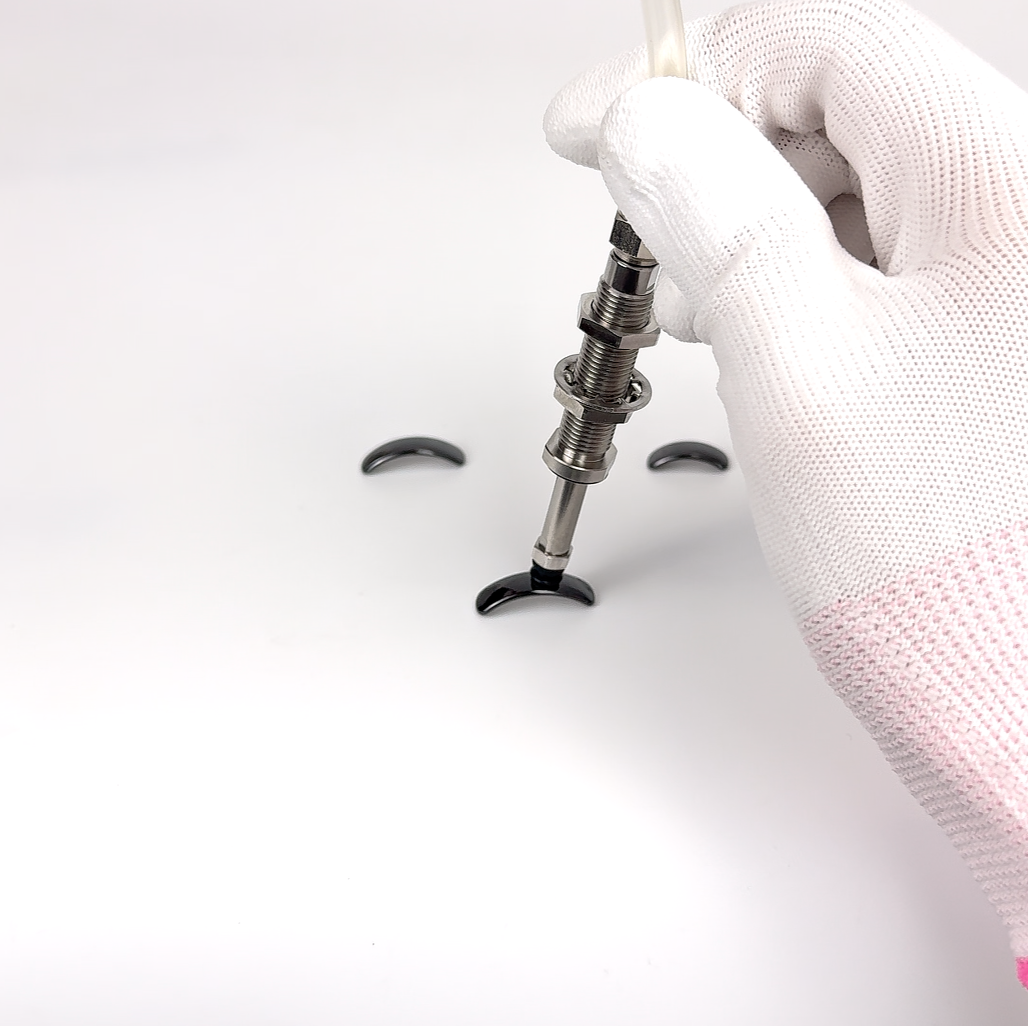
A robot arm end effector represents the critical component that directly interacts with objects and materials in robotic automation systems. The robot arm end effector functions as the hand or gripper of the robotic arm, enabling precise manipulation, grasping, and processing of items across diverse industrial applications. This specialized tool is engineered to perform specific tasks with exceptional accuracy and consistency that surpasses human capabilities.
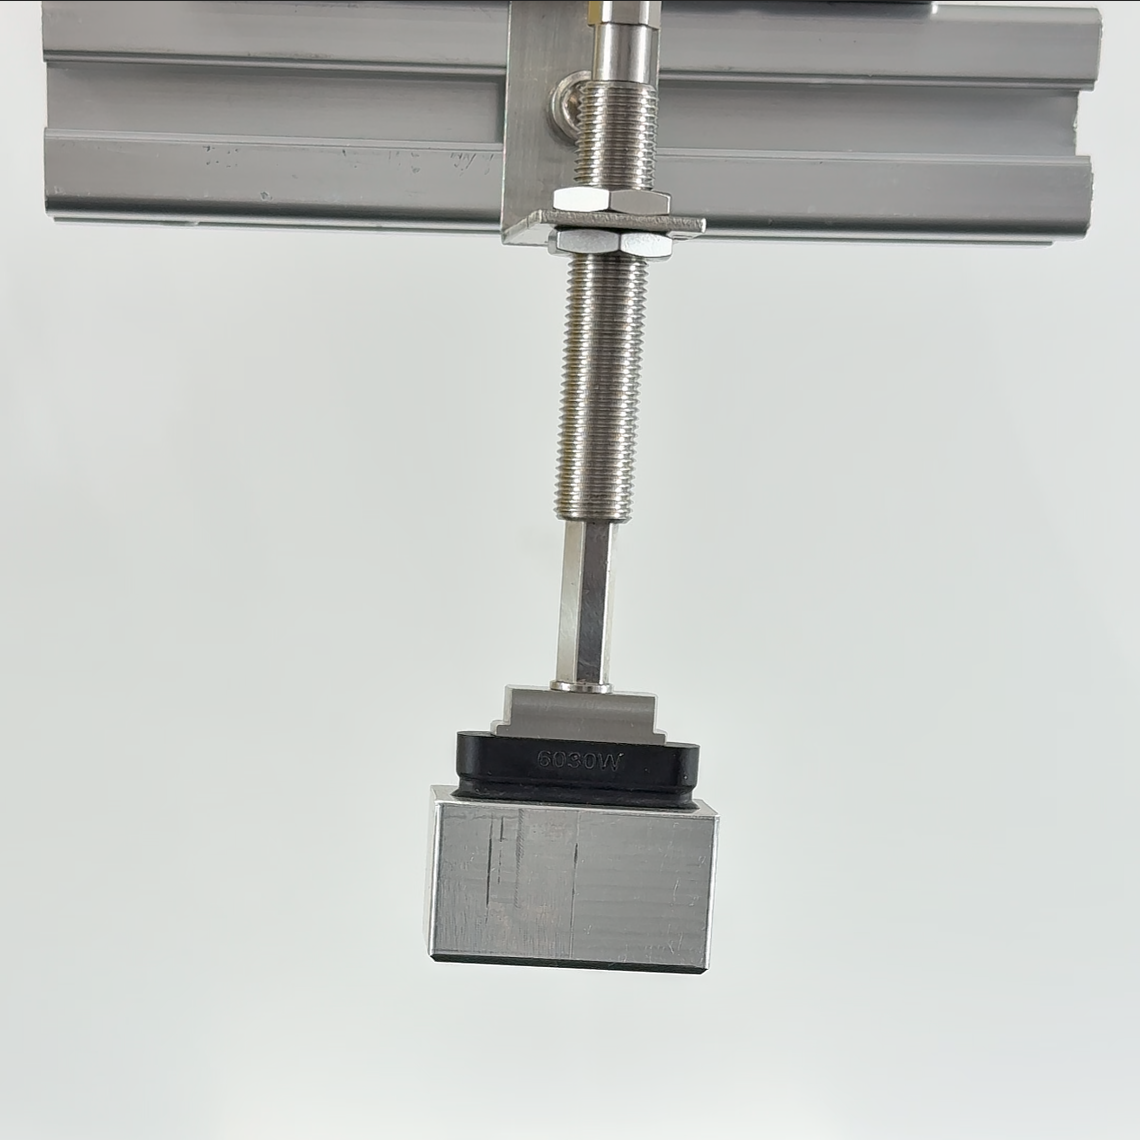
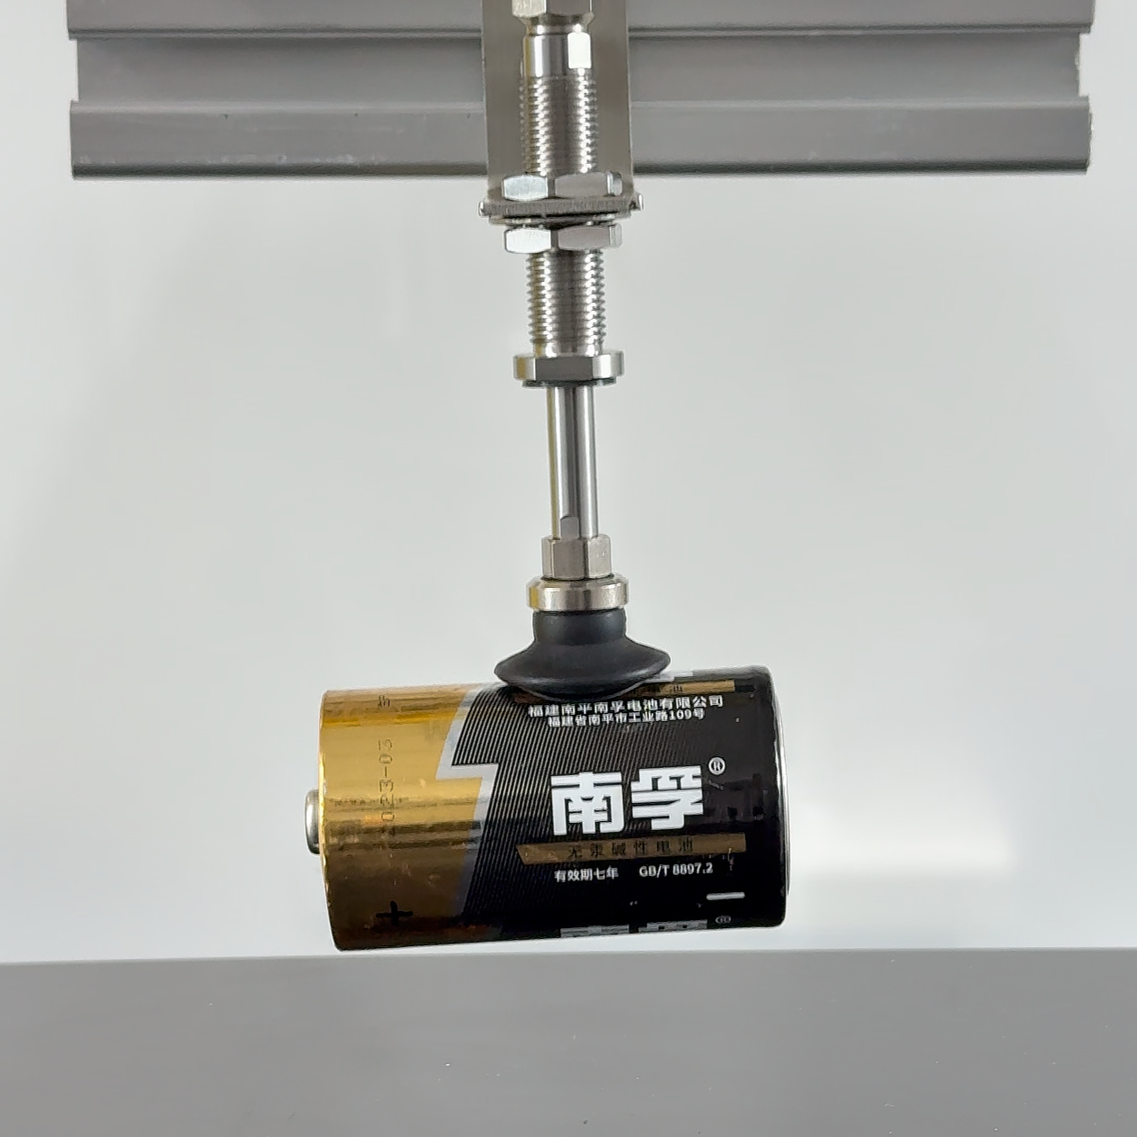
The robot arm end effector incorporates advanced technological features including multi-fingered gripping mechanisms, pneumatic or electric actuation systems, and integrated sensory feedback technologies. These components work synergistically to deliver reliable performance in demanding manufacturing environments. The end effector design accommodates various load capacities and grip force specifications, ensuring optimal performance across different operational scenarios.
Applications for the robot arm end effector span automotive manufacturing, electronics assembly, packaging operations, material handling, and food processing industries. Each application demands specific end effector configurations tailored to unique product requirements and environmental conditions. Modern robot arm end effector systems utilize machine learning and adaptive control algorithms to optimize performance and reduce operational variability.
The integration of the robot arm end effector within collaborative robotic systems enables safer human-machine interaction in shared workspace environments. Advanced sensing capabilities embedded within the end effector allow real-time monitoring and adjustment of grip parameters, enhancing safety and product integrity throughout automated processes.
 EN